russtedrake PRO
Roboticist at Walden Robotics and MIT
Part 1
MIT 6.421
Fall 2026, Lecture 8
Russ Tedrake
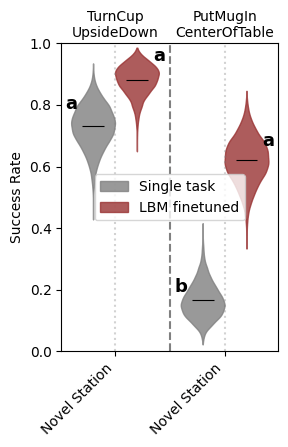
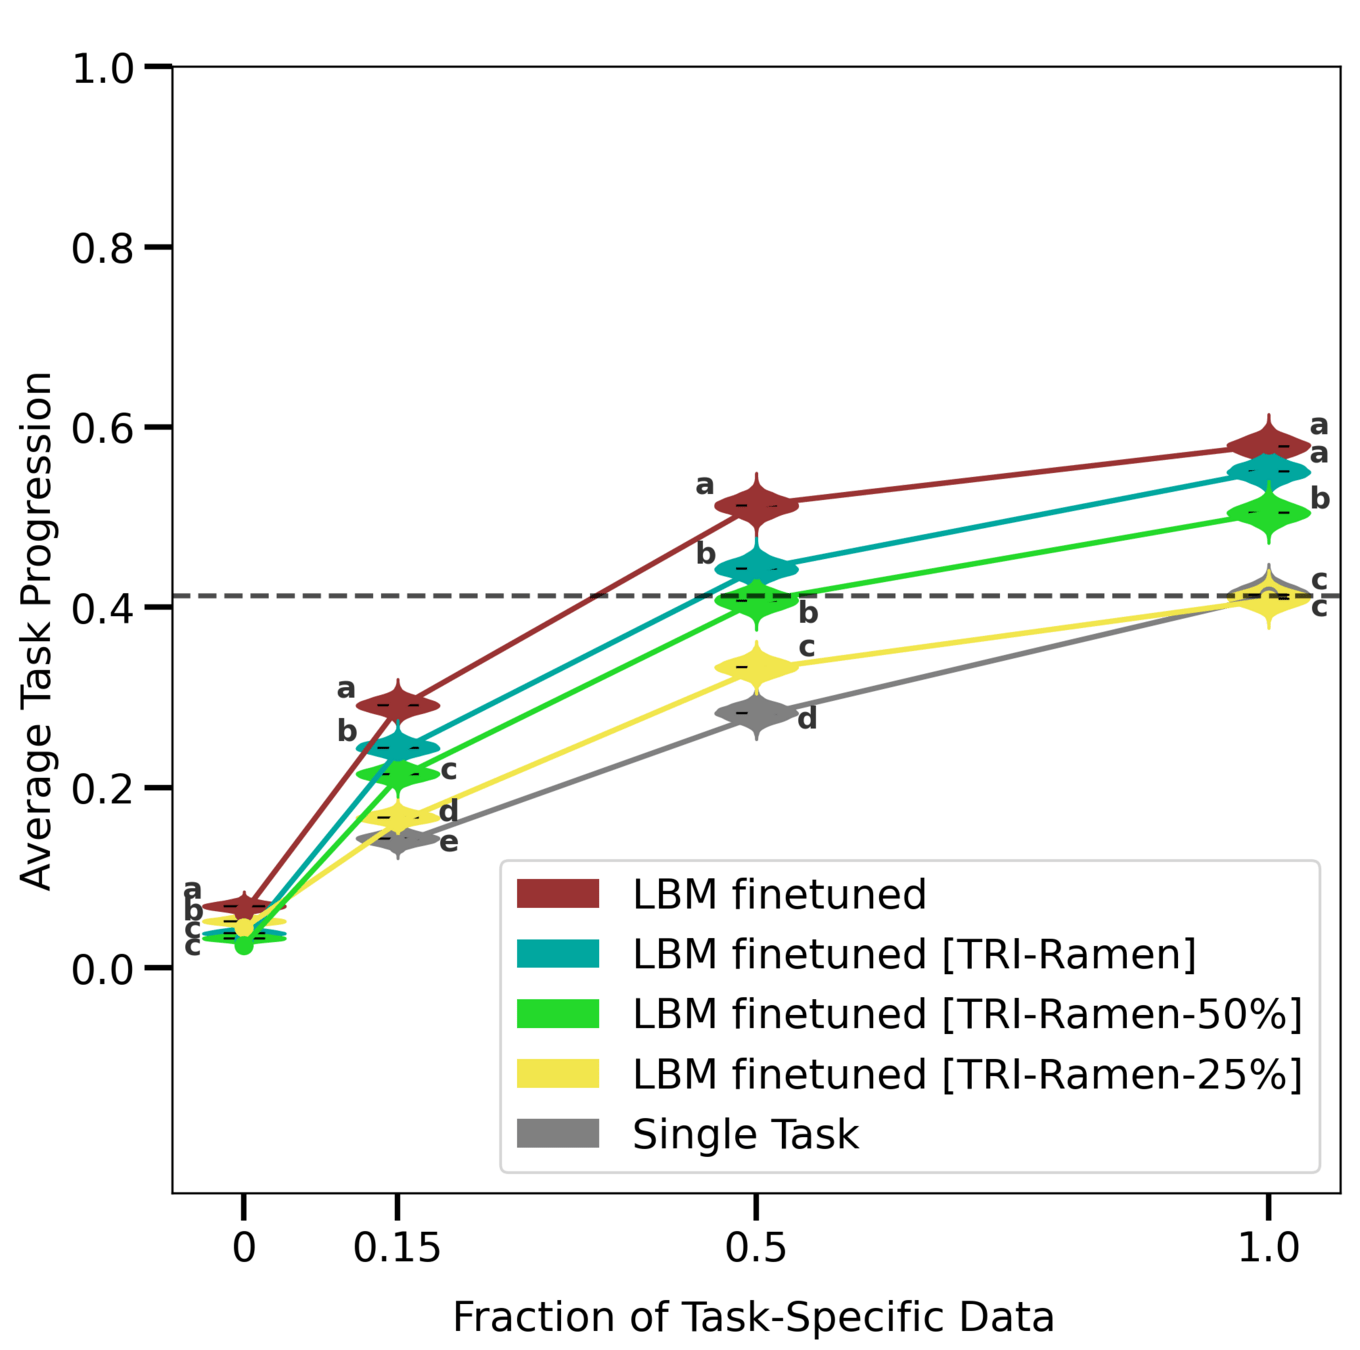
from the LBM 1.0 paper
more data from this task
more data from other tasks
fine-tuning
pretraining
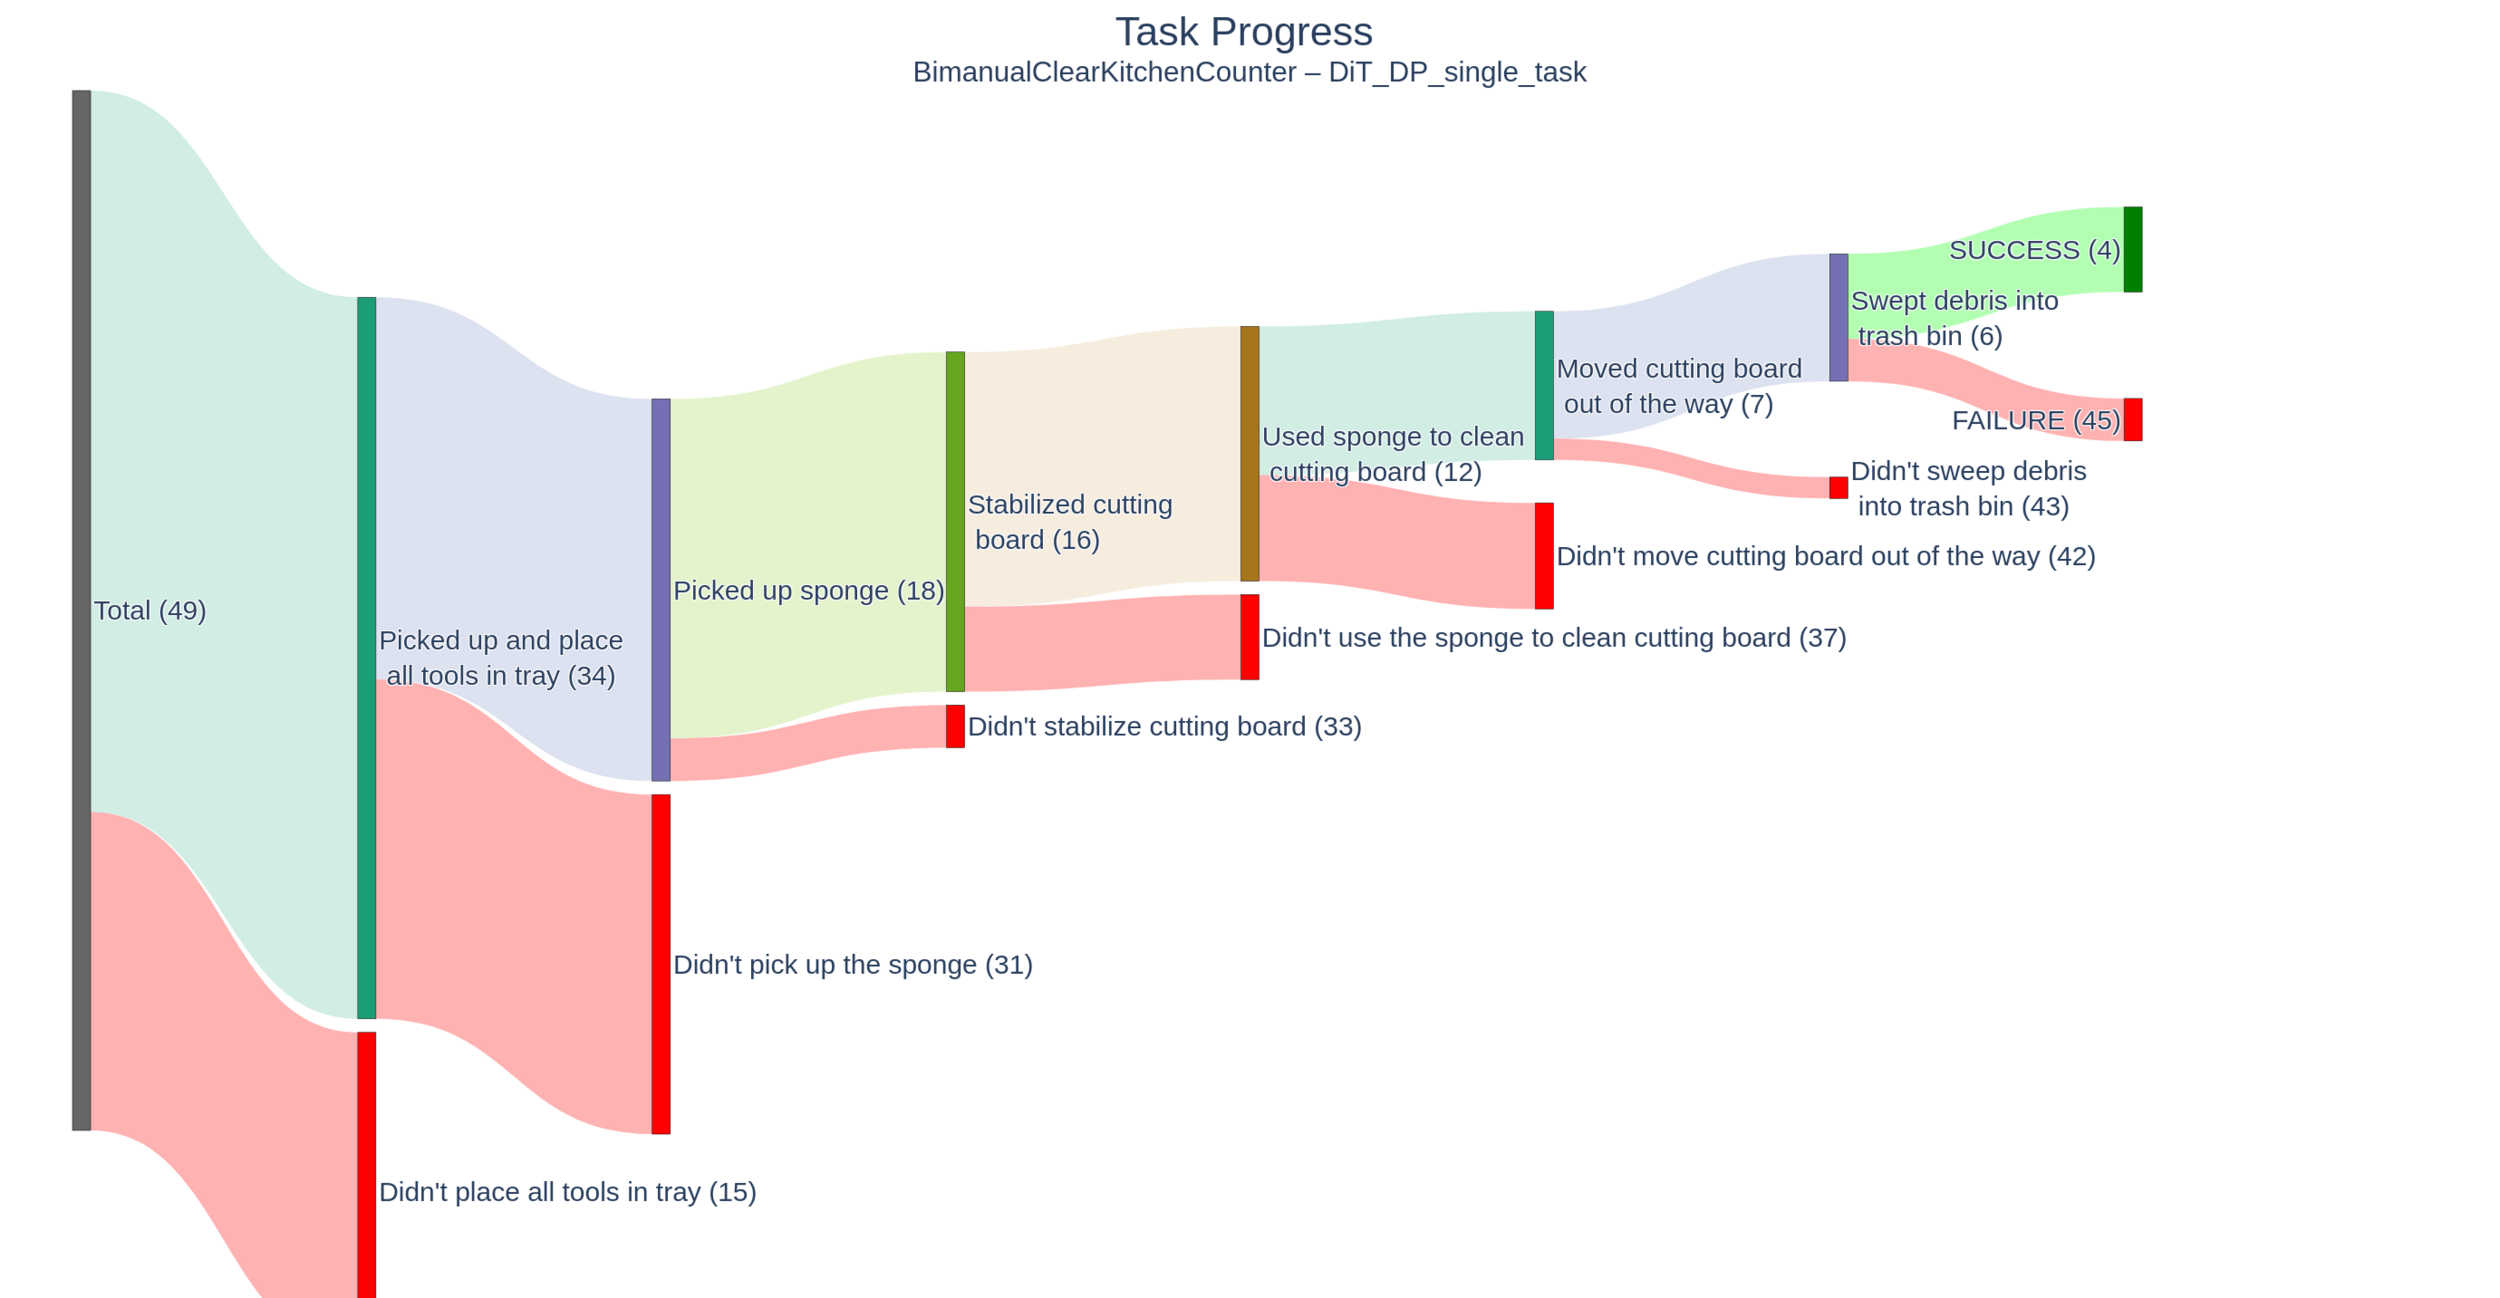
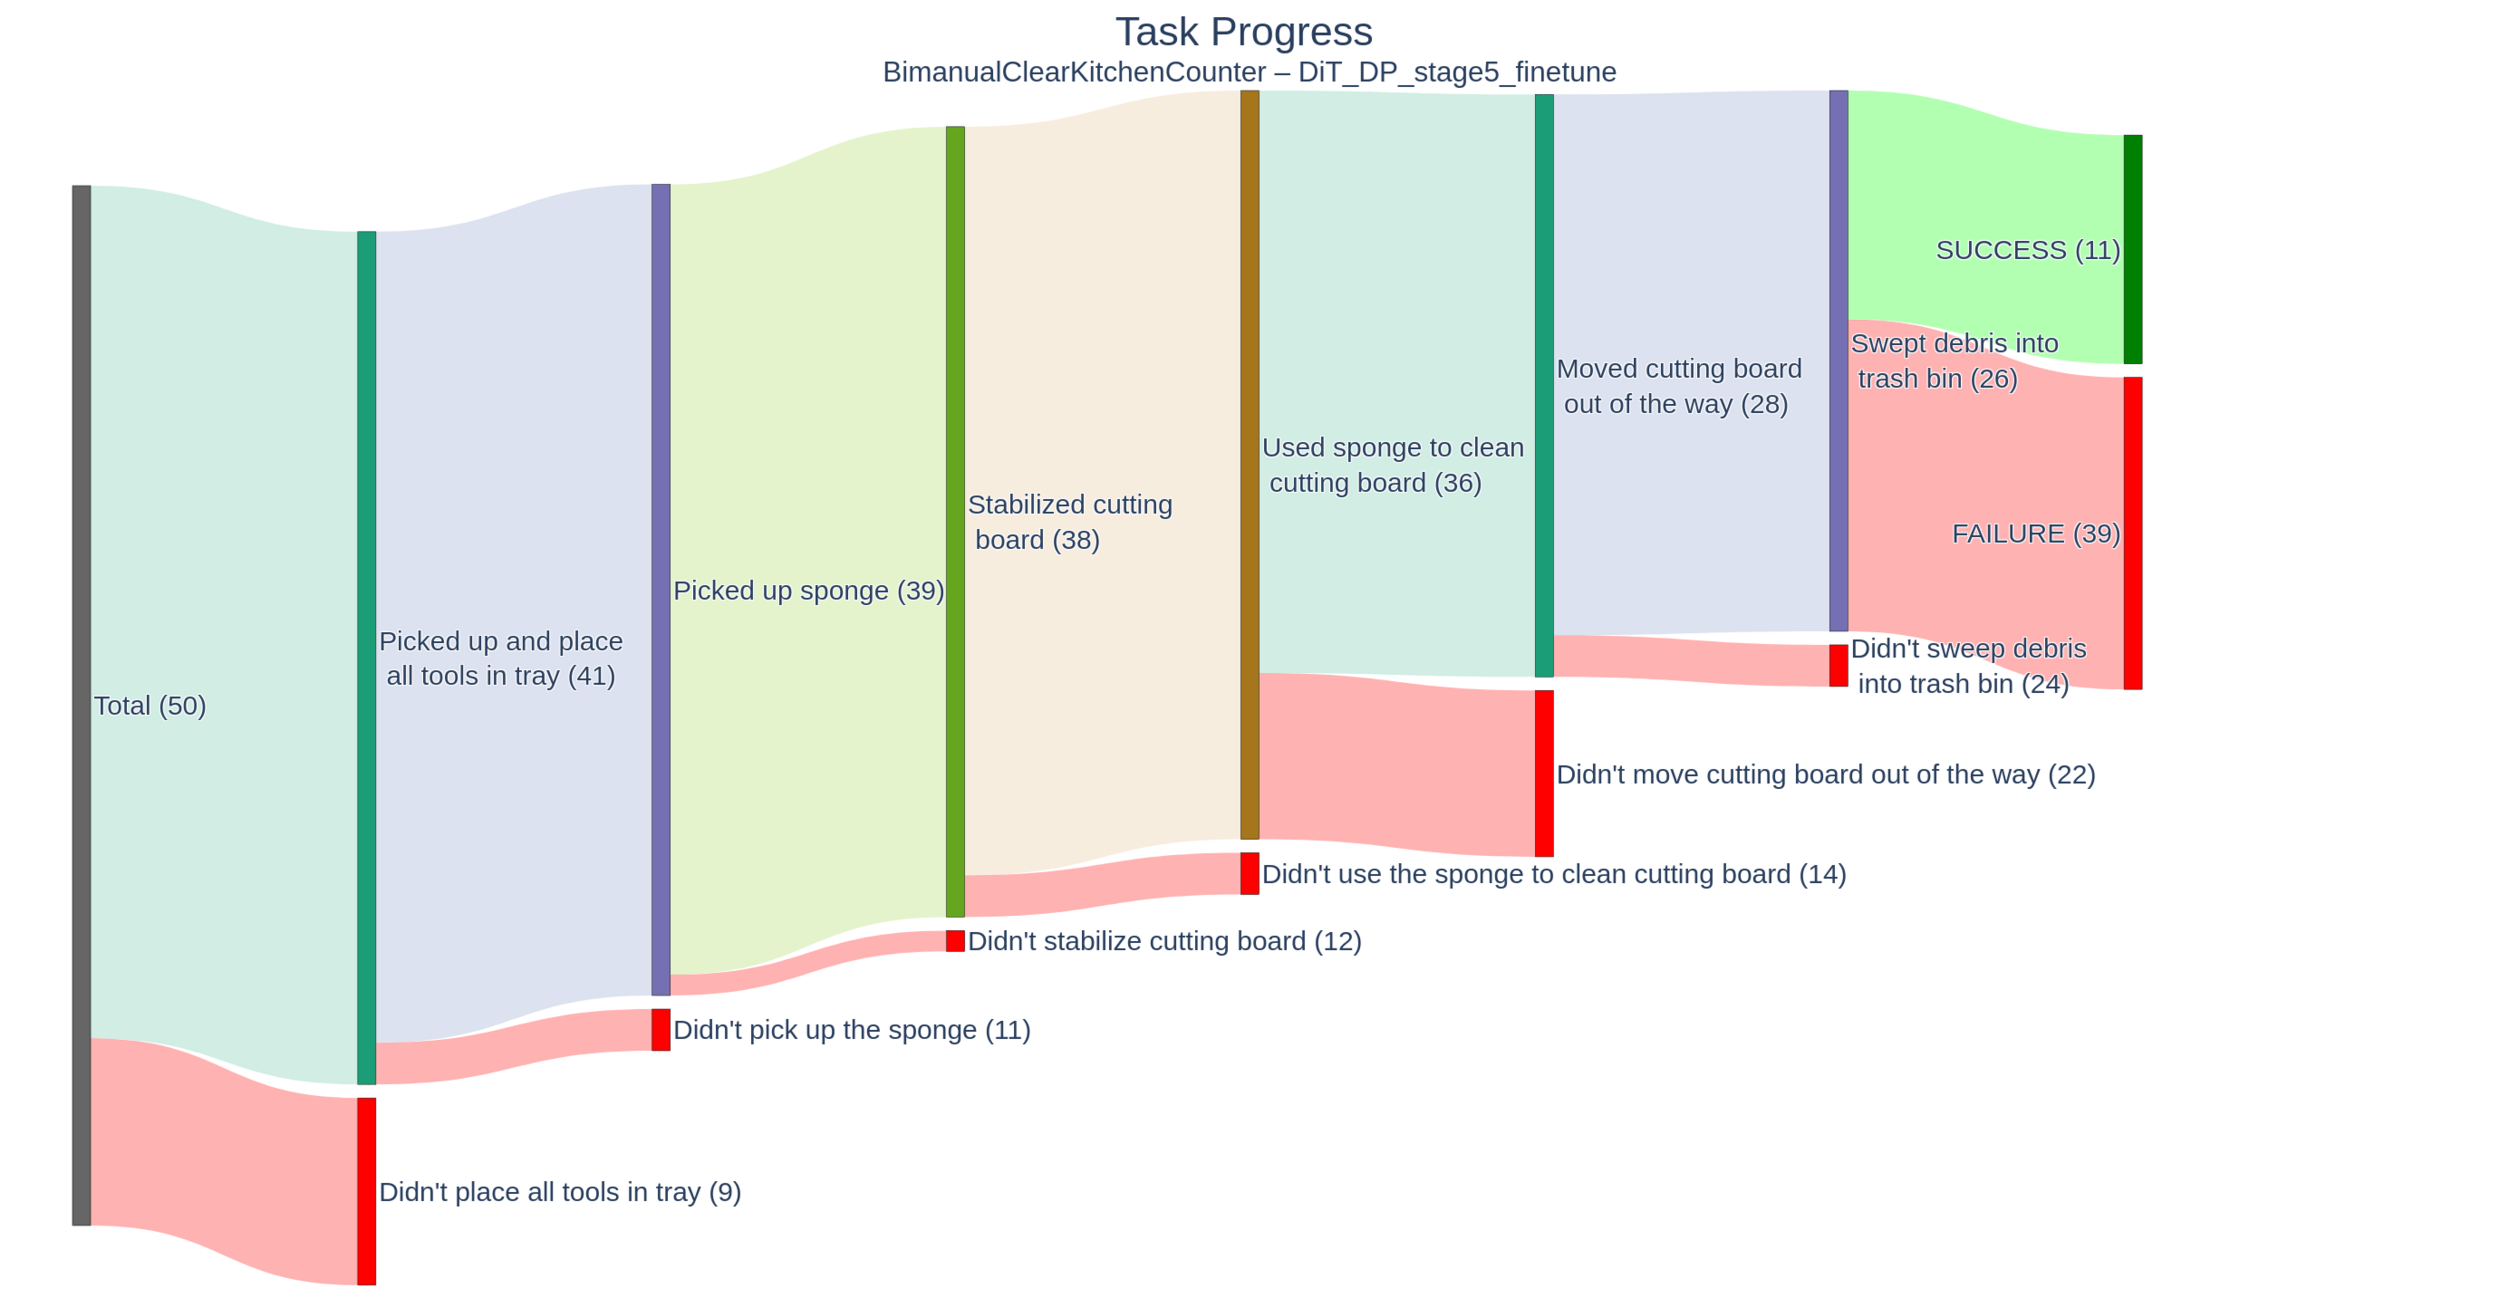
ClearKitchenCounter
Single task
LBM finetuned
Note: It did take 2.5 minutes to run..., so it's a harbinger, but not quite ready to ship...
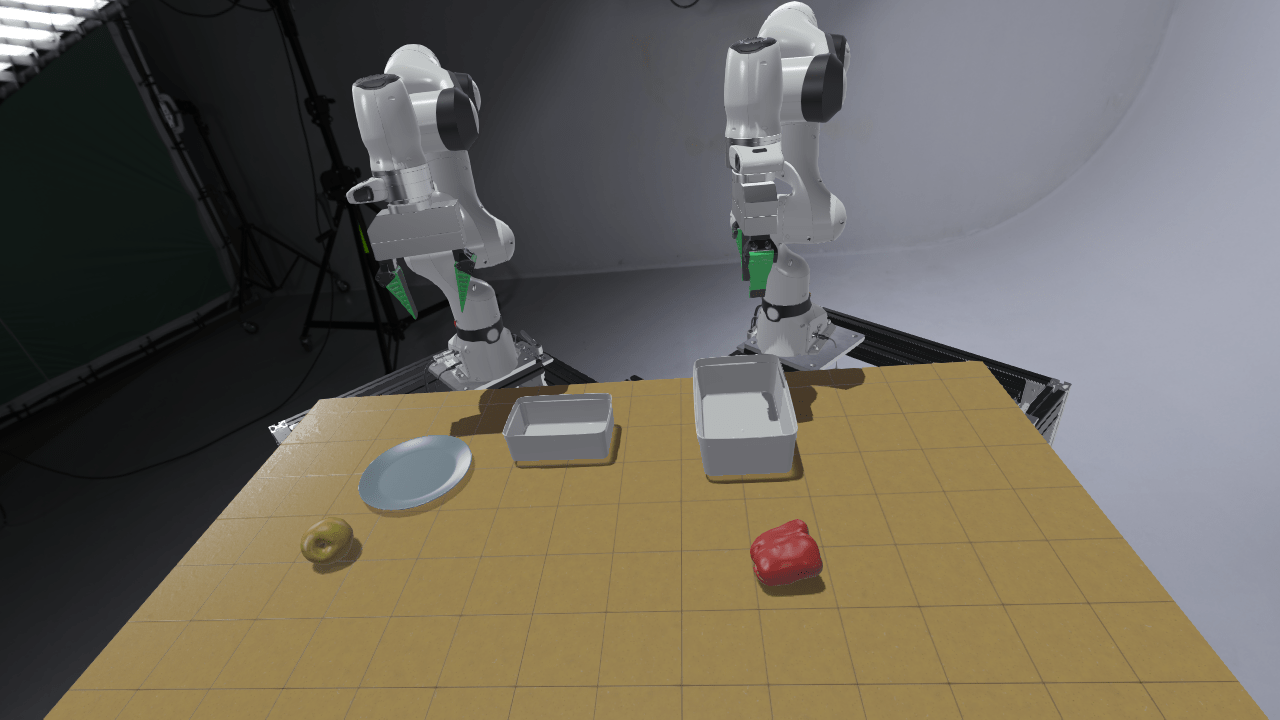
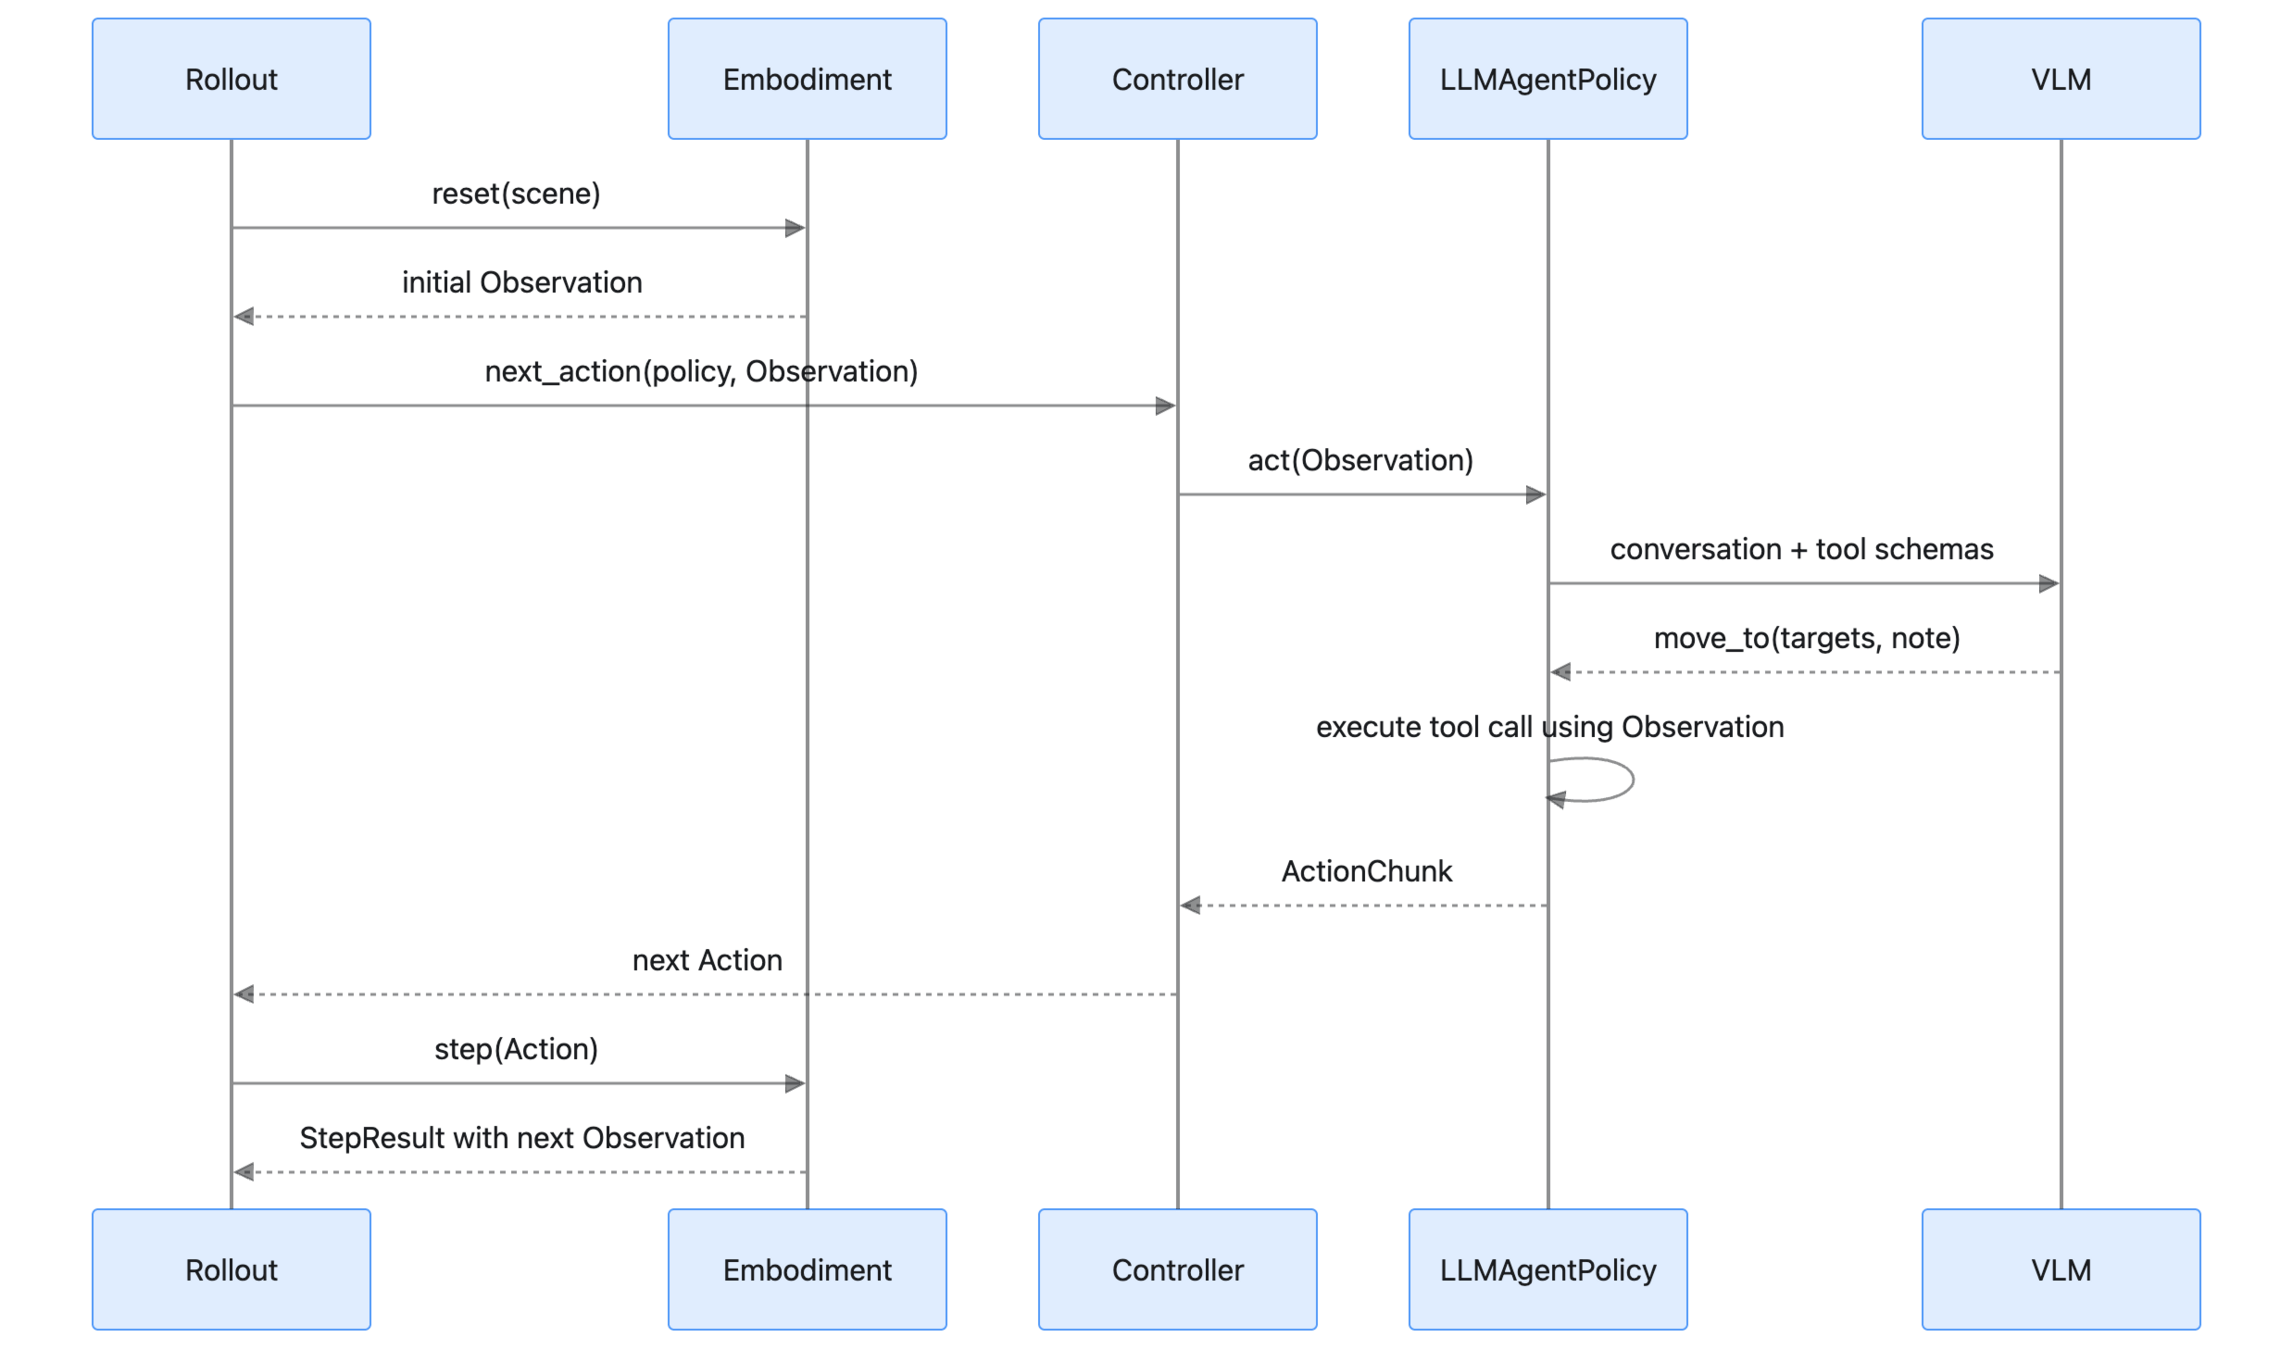
“Pick up the red block from the table and place it inside the bowl” using Inspect Robots
{
  "model": "provider/model",
  "messages": [
    {
      "role": "system",
      "content": "You are controlling a robot through tool calls. Each observation gives you the current state and camera images. Work toward the goal in small motions; re-check the observation after every motion. Every move call needs a note. Respond with exactly one tool call per turn..."
    },
    {
      "role": "user",
      "content": "Goal: pick up the red cube"
    },
    {
      "role": "user",
      "content": [
        {
          "type": "text",
          "text": "Current observation.\nstate[eef_pose]: x=0.31 y=0.12 z=0.40 ...\n"
        },
        {
          "type": "text",
          "text": "camera 'front':"
        },
        {
          "type": "image_url",
          "image_url": { "url": "data:image/png;base64,..." }
        }
      ]
    }
  ],
  "tools": [
    {
      "type": "function",
      "function": {
        "name": "move_to",
        "description": "Move to absolute Cartesian end-effector targets...",
        "parameters": {
          "type": "object",
          "properties": {
            "targets": {
              "type": "object",
              "description": "Map of dimension name to value. Valid names: ..."
            },
            "note": {
              "type": "string",
              "description": "What you observe and why you chose this motion."
            }
          },
          "required": ["targets", "note"]
        }
      }
    }
  ]
}
{
"tool_calls": [
{
"id": "call_123",
"type": "function",
"function": {
"name": "move_to",
"arguments": "{\"targets\":{\"x\":0.30,\"y\":0.10,\"z\":0.25},\"note\":\"The gripper is above and to the side of the cube, so I’m moving over it before lowering.\"}"
}
}
]
}Example VLM prompt:
Example VLM response (tool call):
{
  "targets": {
    "x": 0.30,
    "y": 0.10,
    "z": 0.25
  },
  "note": "The gripper is left of the cube, so I’m moving above it before lowering."
}By russtedrake
MIT Robotic Manipulation Fall 2026 http://manipulation.mit.edu